Season by season
Season Journal
What we did, in order. Newest season first; within a season, oldest entry first. There's a template in the page source.
2026–27
Kickoff was this month. Entries start as soon as we have photos worth showing.
2025–26 · DECODE
-
13Sep 2025
Kickoff
First meeting of the DECODE season. We read the game manual, argued about strategy, and got a to-do list on the whiteboard: launcher, drive train, intake, storage, camera. Someone sketched a chassis on graph paper and by the end of the day there was a base frame with two motors and a test station for the programmers.
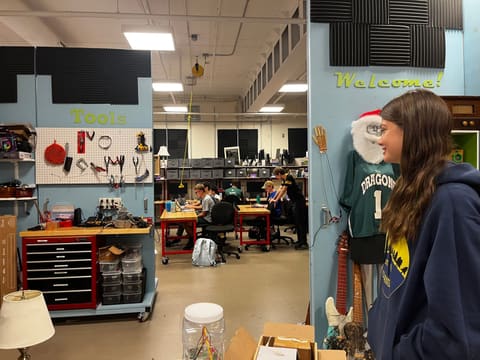
Day one 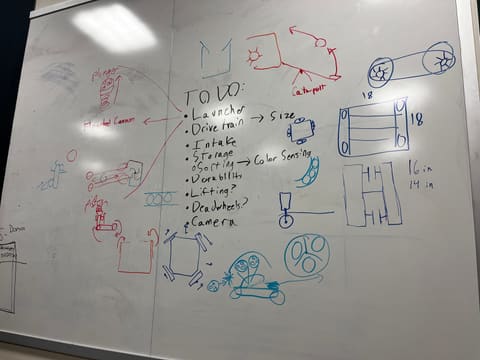
The to-do list 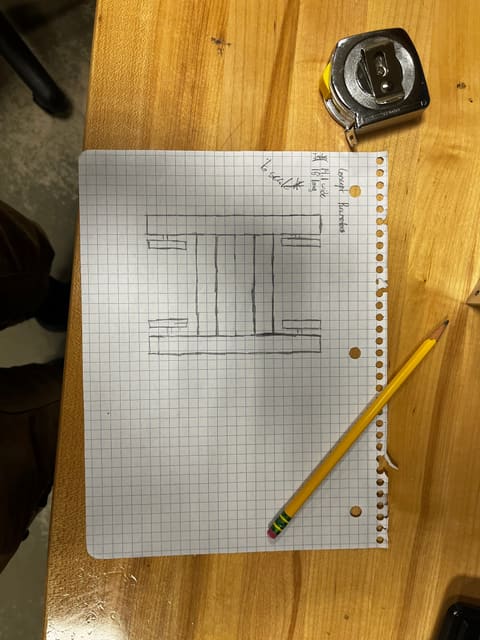
Chassis sketch 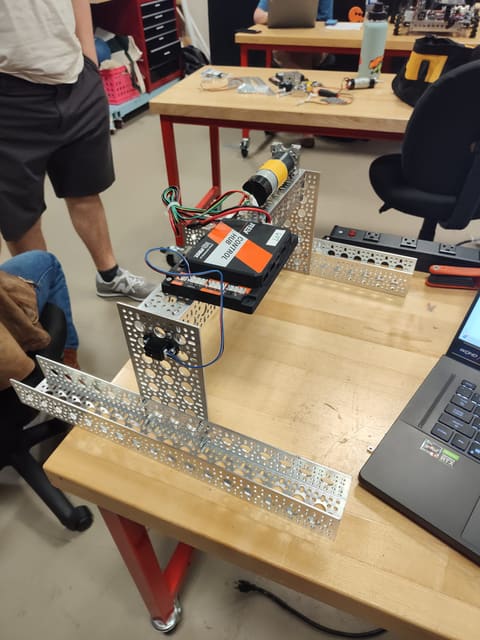
First test station -
17–26Sep 2025
Chassis types, launcher drawings, AprilTags
We compared H-frame, A-frame, triangle and box frames on the whiteboard and picked the one that gave us the most room for mechanisms. The mechanical group drew the first launcher and built a rough flywheel prototype out of two motors and a channel. The programmers got AprilTag detection running on the rough chassis by Friday.
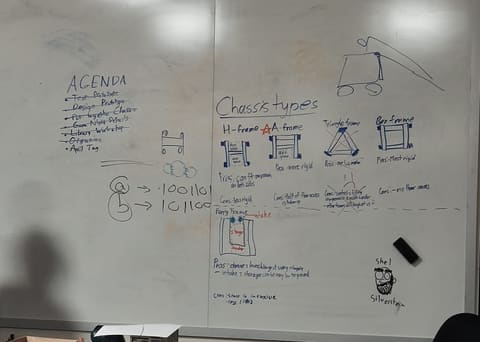
Chassis options 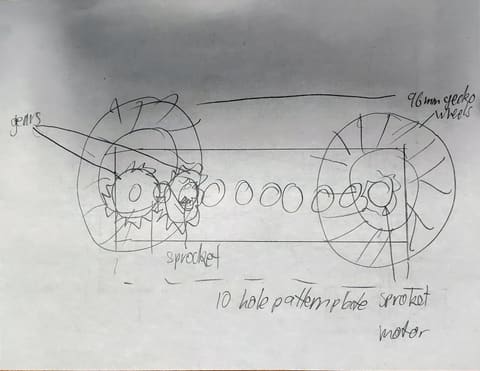
Launcher drawing 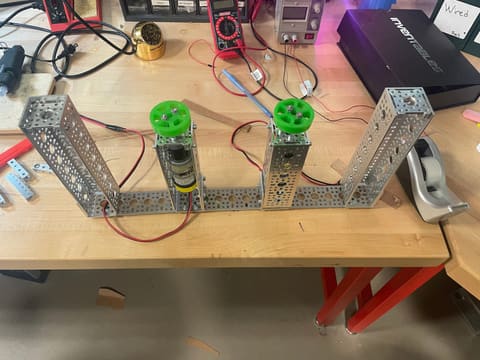
Flywheel prototype 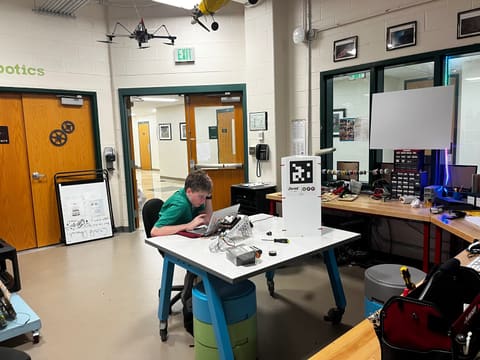
AprilTags working -
27Sep 2025
Family Day
Families came to see the shop. We built a goal ramp and a second test station, and took the chassis outside to drive on the giant floor map on the court. More on the outreach page.
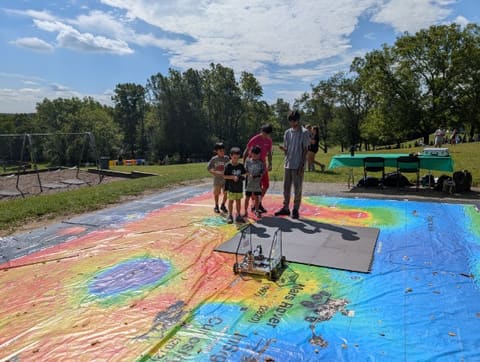
Driving on the giant map 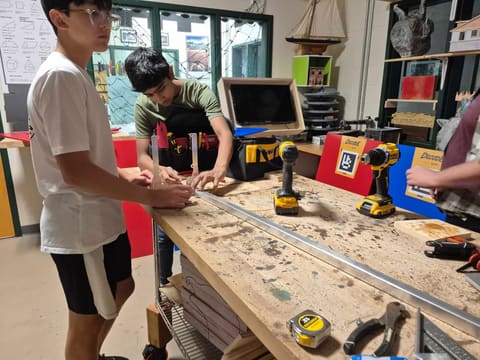
Building the goal ramp 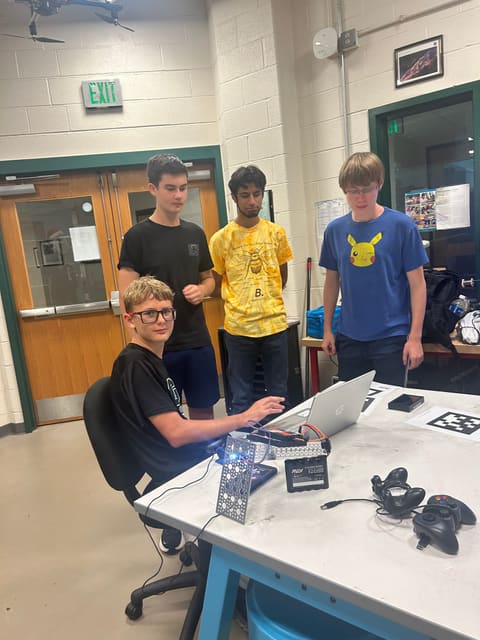
The coding team -
4Oct 2025
Prototyping Saturday
Cardboard everywhere. We built a cardboard drum to see how three artifacts would sit in it, a twin-spinning-bar intake, and a "kicker" to push artifacts into the drum from the side. None of it was pretty and all of it taught us something. The prototype bot got a face.
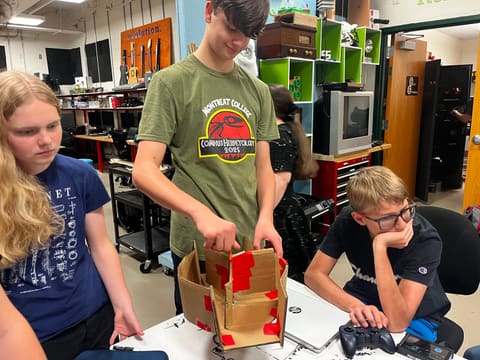
Cardboard drum 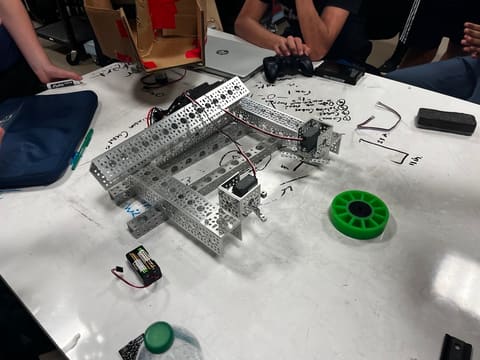
Spinning-bar intake 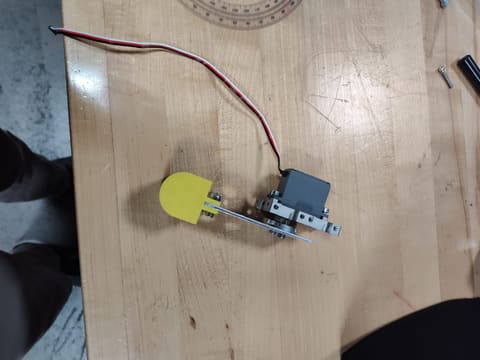
The kicker 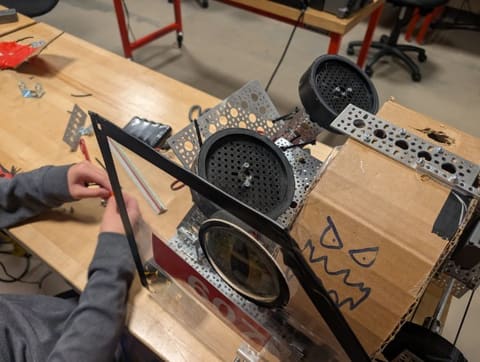
The prototype bot -
18Oct 2025
Solar Science Day
An outreach day on campus with telescopes, a meteorites table, the county library's STEAM Machine bus, and a Go2 robot dog that our chassis got to meet on the pavement. Visitors took turns driving. More on the outreach page.
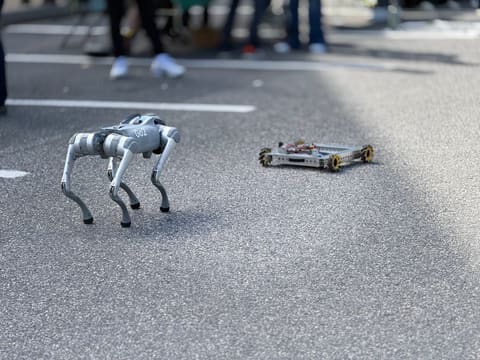
Robot dog meets chassis 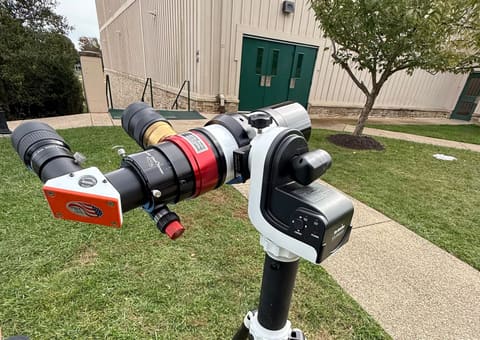
Solar telescope 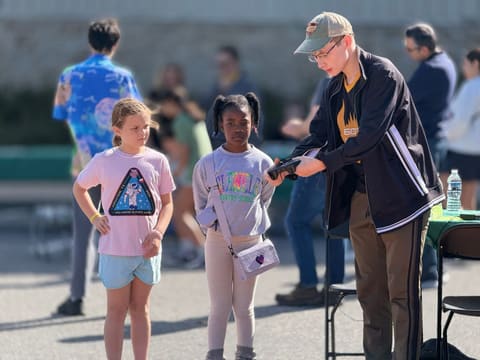
Visitors driving -
LateOct 2025
Doing the math
Before committing to the flywheel we worked out the launch physics on the whiteboard: exit speed, angle, and how far off we could be and still score. We also wrote down our design loop so everyone was using the same words for it: idea, discuss and plan, build a prototype, test, go around again. Road Runner tuning moved into the hallway, where the floor is flat.
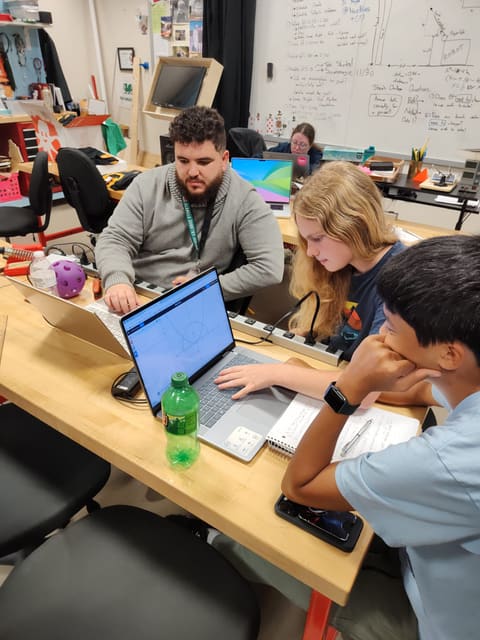
Working through the physics 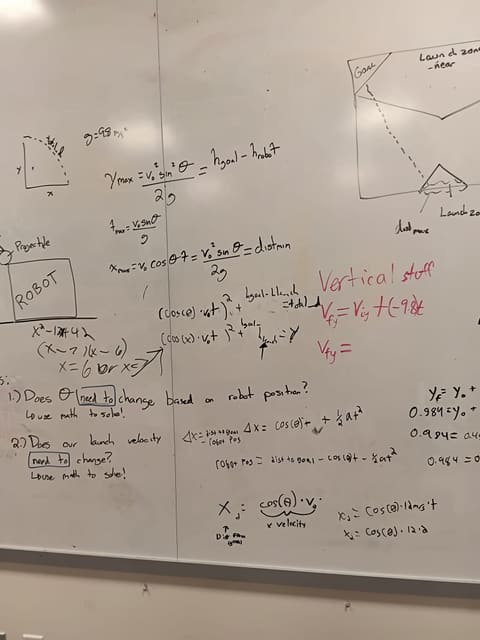
Trajectory equations 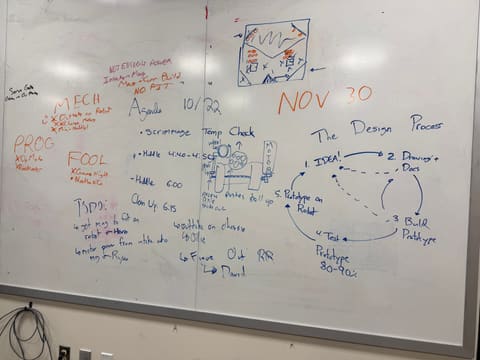
The design process 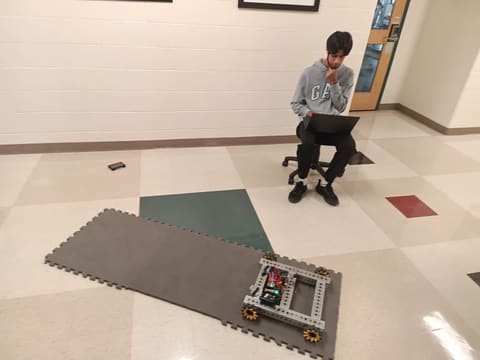
Road Runner in the hallway -
1–5Nov 2025
The new drum
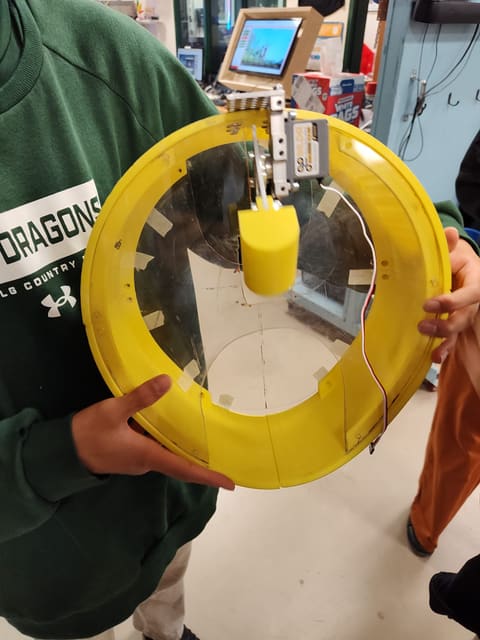
The cardboard drum retired. We printed a ring in sections, mounted it on a plexi face, and printed brackets to hold it. While the drum was off, we moved the Control Hub and Expansion Hub to places you can reach without taking anything apart, and found one missing bearing that explained a wobble.
The new drum 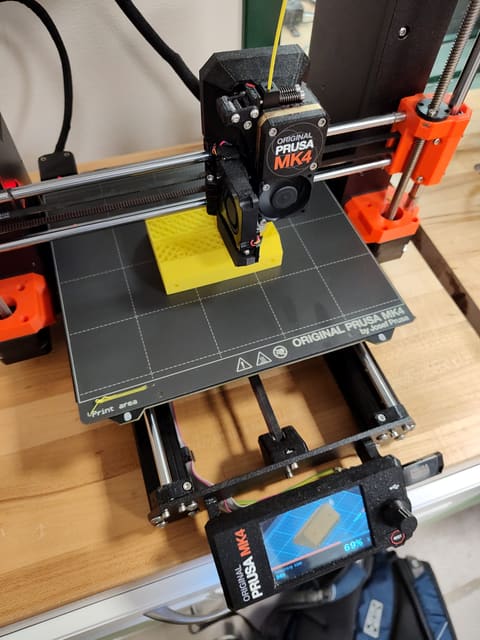
Printing brackets 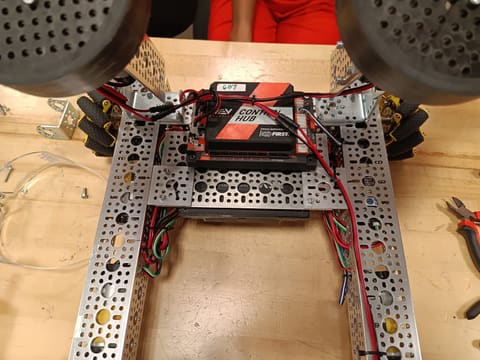
Control Hub moved 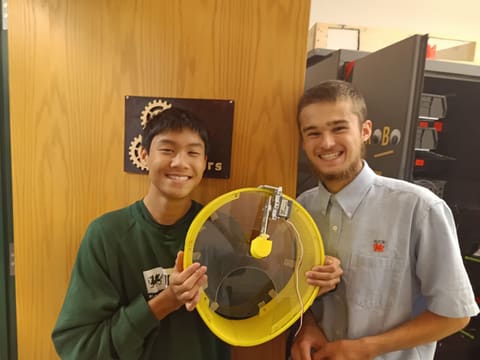
Finished drum -
10Nov 2025
Plywood and dead wheels
We cut a plywood disc to close off the drum, and mounted two odometry dead wheels with encoders under the chassis so the robot can track its position separately from the drive wheels.
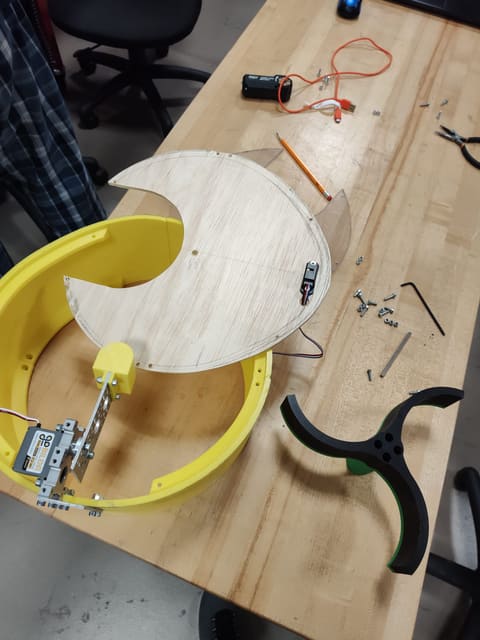
Plywood disc 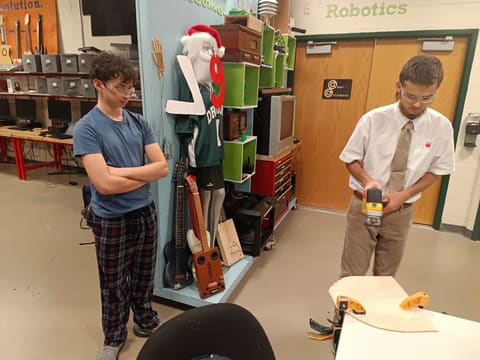
Cutting plywood 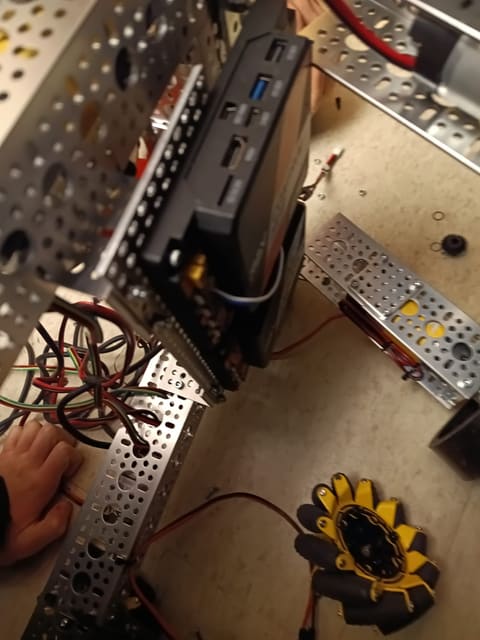
Dead wheel -
14Nov 2025
Game Night
Our fundraiser in the Forum: retro games on the big screen, ping-pong, snacks. Before we set a ticket price we simulated attendance and costs ten thousand times to find a break-even point. It worked. More on the outreach page.
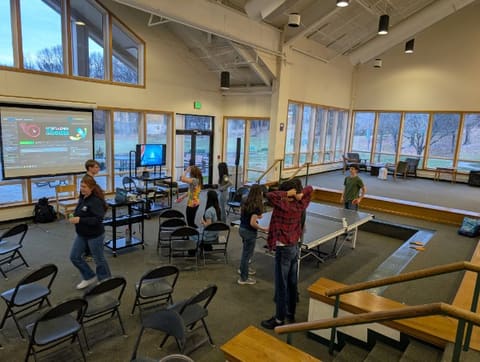
Game Night 
Big screen 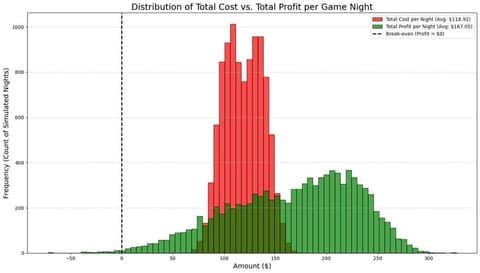
Cost vs. profit simulation -
MidNov 2025
Intake, side panels, portfolio
Three things at once. The mechanical group heat-gunned plexi into intake guides and printed a fresh set of cheese wheels; by the end of one Saturday the intake fed the drum for the first time. The side panels got their 607 number plates. And the portfolio team mapped out the engineering portfolio page by page on the whiteboard.
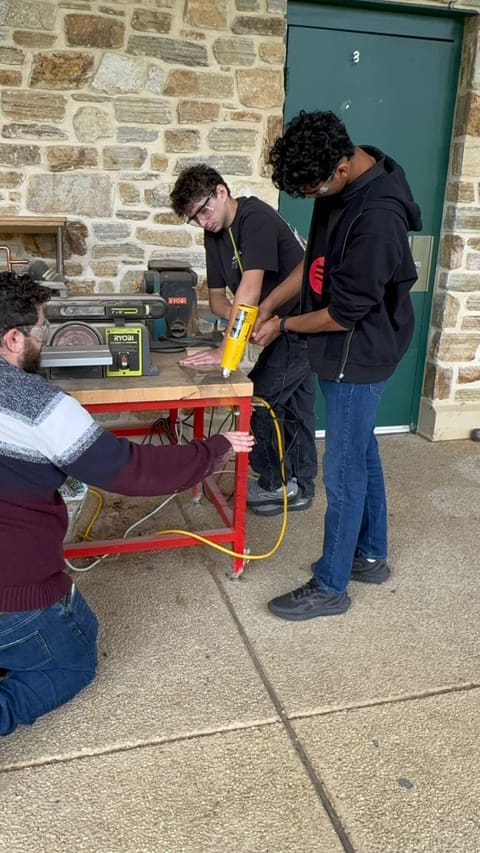
Heat-gunning plexi 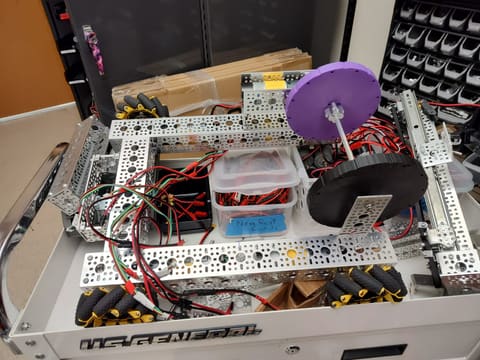
Intake by end of day 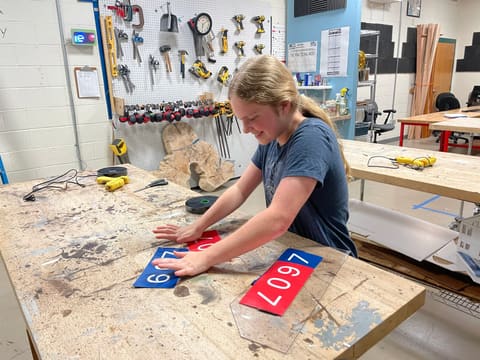
Team number plates 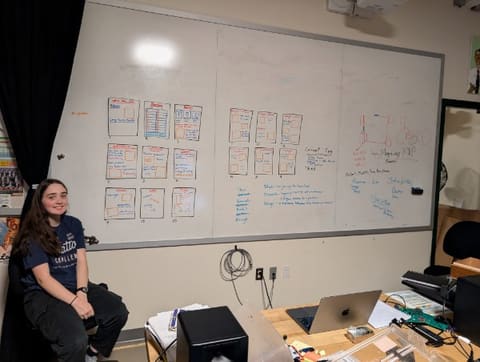
Portfolio plan -
22Nov 2025
Wiring and batteries
Drum and launcher fully wired, a battery mount sketched and built, spare motors tested. One of us also spoke with a Maryland representative as part of the National Robotics Summit.
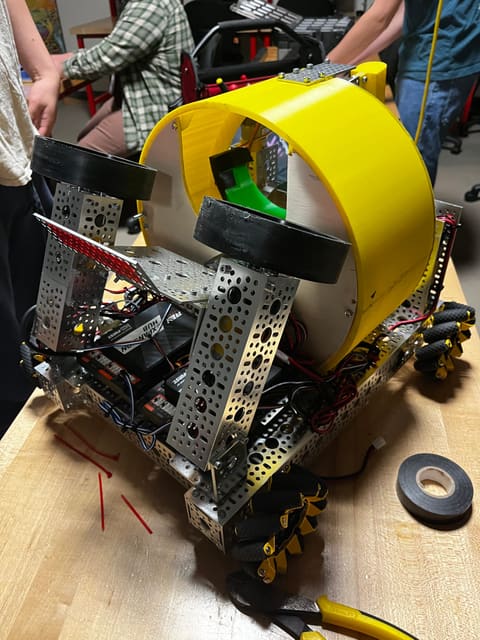
Wired up 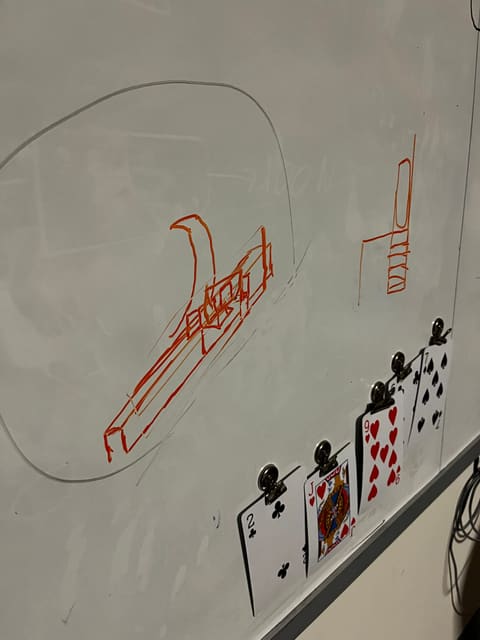
Battery mount sketch 
National Robotics Summit -
29Nov 2025
Practice field
The day before the scrimmage we taped a field onto the shop floor and drove full cycles until the drivers stopped thinking about the controls.
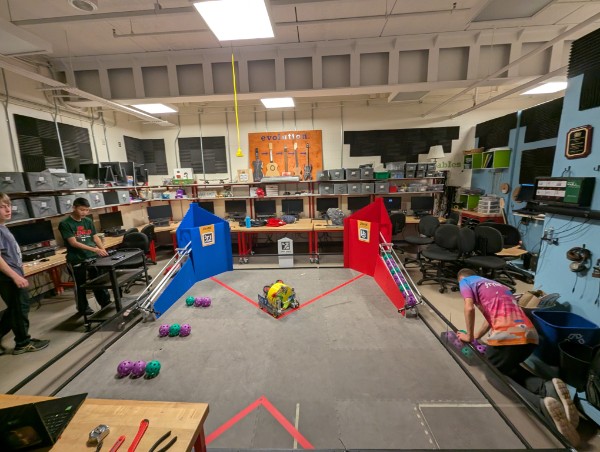
Practice field Running cycles -
30Nov 2025
Scrimmage
Our first matches against other Maryland teams. The drum indexed, the launcher launched, and we learned which parts of the robot come loose when it drives over a field tile seam at speed. Everyone came home with a to-fix list.
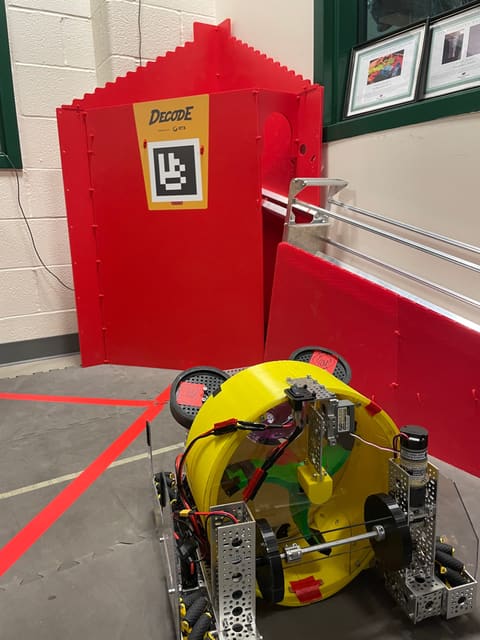
At the goal 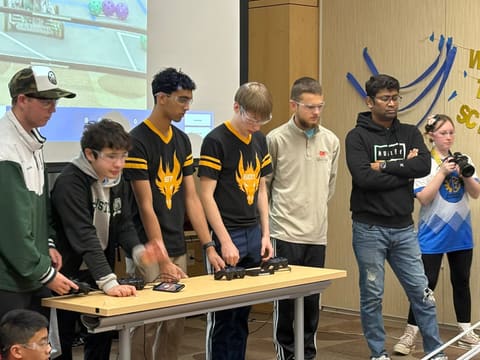
Drive team 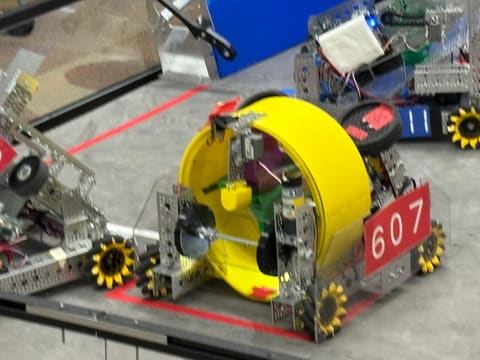
Launching 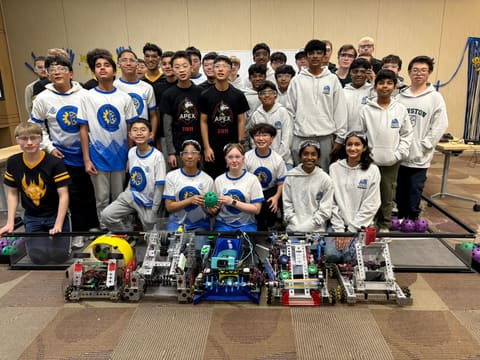
All teams -
Dec–Jan2025–26
Around the shop
Back in the shop after the scrimmage: tuning with FTC Dashboard, tidying the wiring, and mounting a Limelight camera in January.
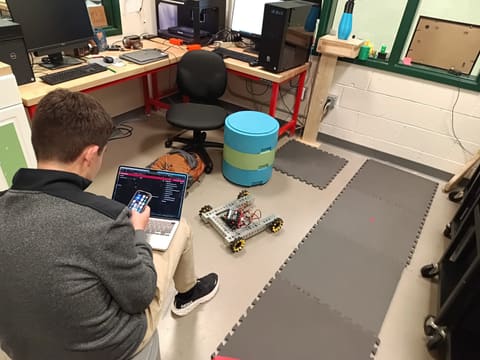
FTC Dashboard 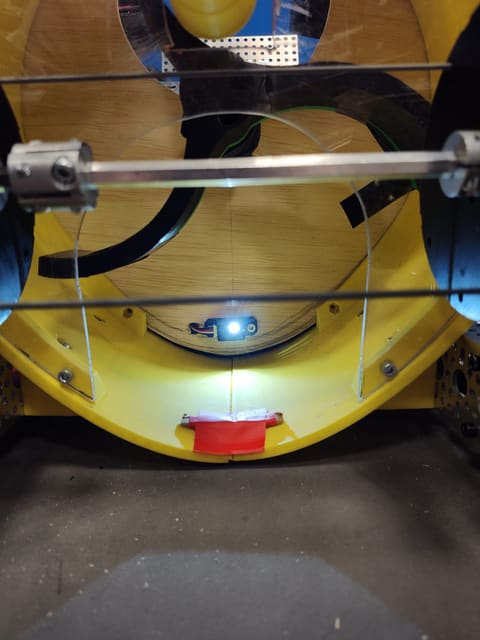
Inside the drum 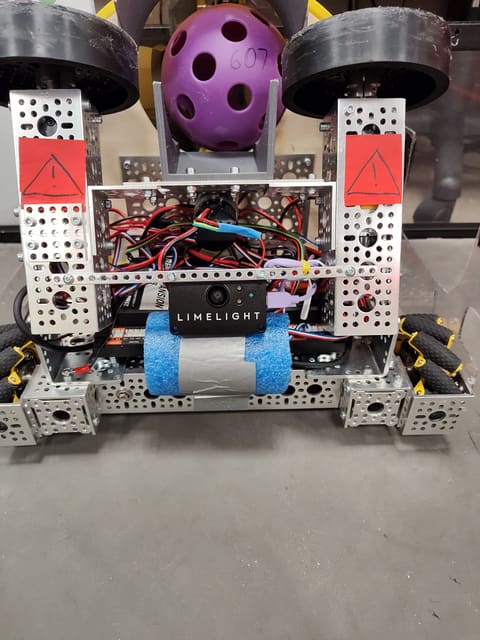
Limelight, January